The PartNet-Mobility Illusion: Why Visual 3D Meshes Shatter in Simulation
Every robotics operator who has loaded an asset from Objaverse, 3D Warehouse, or even PartNet-Mobility into Isaac Sim or SAPIEN has lived the exact same frustration. The cabinet or desk looks clean in Blender. The textures render beautifully, the topology passes basic inspection, and the semantic segmentation masks look crisp. But the moment you spawn the entity into a rigid-body physics engine and actuate a joint, the entire asset disintegrates.
Doors swing through carcass side panels. Drawers pull out into empty space with zero friction stops before free-falling to the floor. Worst of all, door rotation axes float mid-air five centimeters outside the cabinet face because the original artist modeled the front panel flush against the frame without a millimeter of gap or a single hinge pocket. In our earlier work on rigging pipelines—such as turning static geometry into articulated characters—we saw how visual meshes mask kinetic impossibilities. In robotics, however, the penalty is immediate: simulation solvers hit instant interpenetration errors, generate massive velocity spikes, and lock up.
Visual 3D Asset (Blender/CG)       Kinematic Estimators (OPD/Ditto)       Physical Reality (Simulator)
+-----------------------+          +-----------------------+              +-----------------------+
| Flush Door Panel      |   --->   | Virtual Revolute Axis |     --->     | Mesh Collision!       |
| No Hinges / Rails     |          | Floating in Void      |              | Joint Clamped / Binds |
| Hollow Carcass        |          | Zero Physical Support |              | Door Cannot Open      |
+-----------------------+          +-----------------------+              +-----------------------+
The dominant paradigm in academic literature has been pure kinematic estimation: taking tools like OPD, OPD_Multi, or Ditto to predict abstract joint parameters—a 3D origin, an orientation vector, and min/max angular limits. I believe this abstraction is fundamentally broken for physical robotics.
Predicting a virtual mathematical ray in empty space without modeling the mechanical hardware that justifies that ray is an illusion. Real cabinet doors do not rotate around a floating line; they rotate because a stamped-steel concealed hinge or continuous pivot enforces that trajectory while physically stepping the door outward to clear the carcass edge. When you omit the hardware, simulation checkers are forced into a terrible compromise: either permit self-intersecting meshes or clamp the joint range down to a useless twenty-degree swing to prevent collision.
This is why I find the formulation behind Functionalization and its underlying model, GraFu, compelling. Instead of treating articulation as an isolated vector prediction task, GraFu frames asset repair as a functional graph completion problem. If an asset is missing the physical structures that make motion possible, the model synthesizes those missing nodes and edges directly into the relational scene graph, turning visual hollow shells into mechanically grounded assemblies.
Deconstructing GraFu: From Relational Graph Transformer to Slot-Decoded Assembly
GraFu tackles structural deficiency by operating directly on a relational part graph rather than attempting monolithic mesh generation. The core insight is that mechanical objects are assemblies of functional relationships: rigid attachments, sliding interfaces, rotational hinges, and resting contacts.
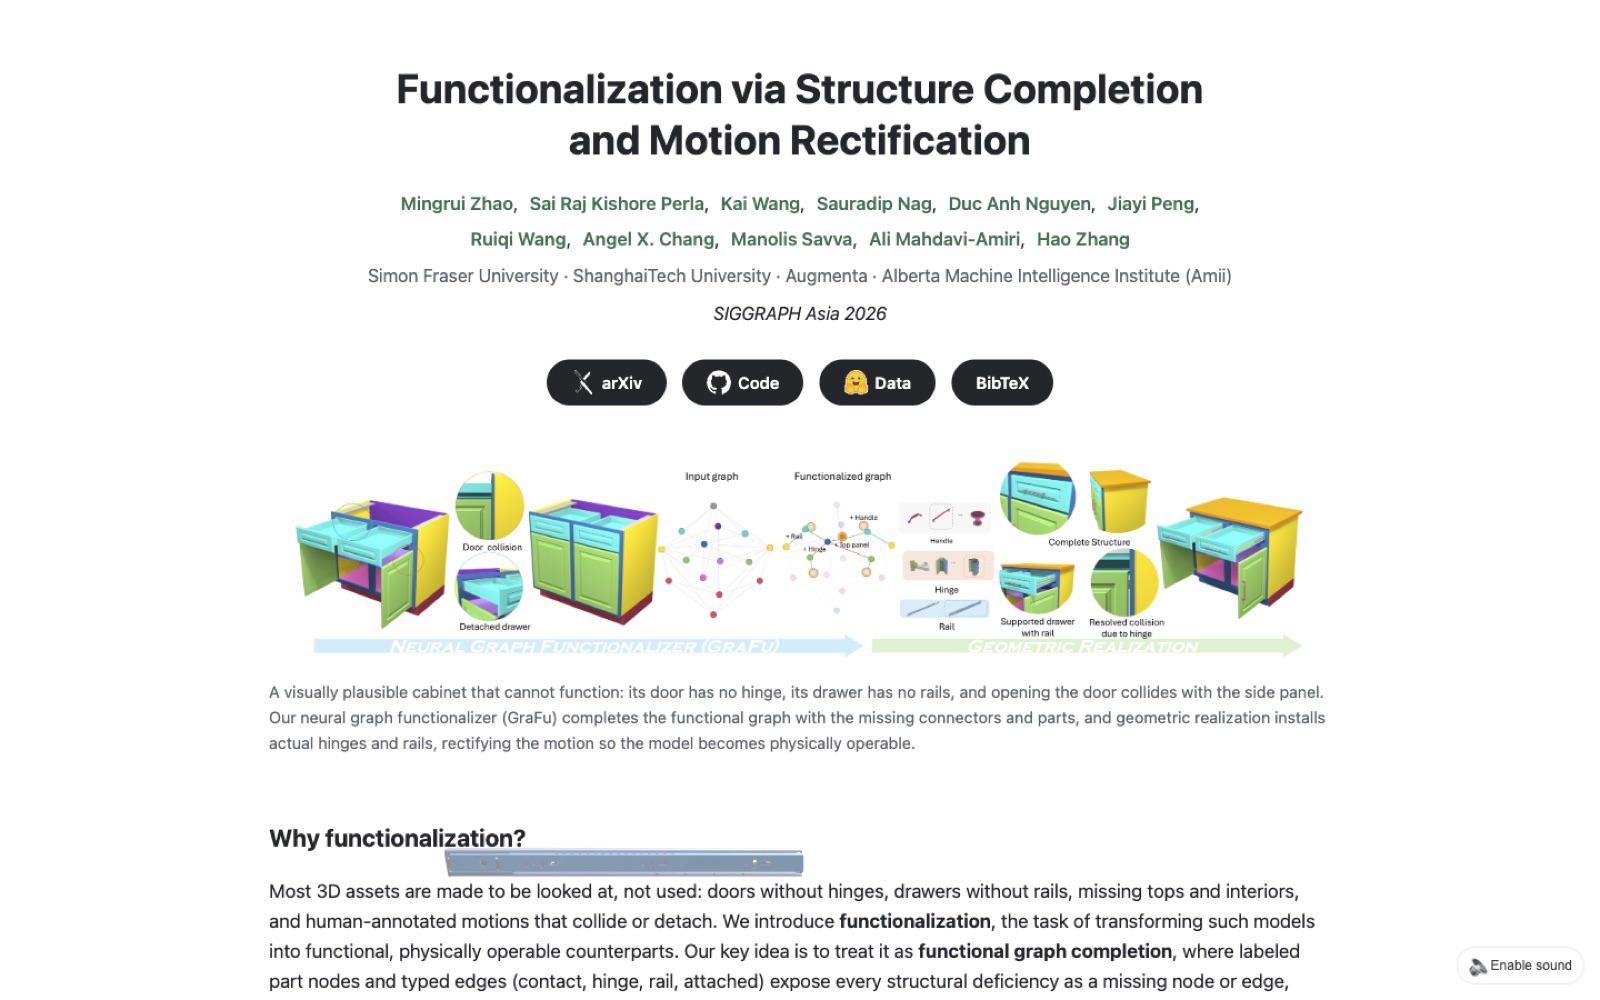
The architecture takes an initial, possibly incomplete set of segmented 3D parts. Each known part node $i$ is encoded through three distinct feature modalities: its semantic category token, a 3D bounding box parameterizing its spatial extent and pose, and a sampled 3D point cloud capturing its raw surface geometry. A PointNet++ backbone extracts structural embeddings from the point clouds, which are concatenated with the bounding box and category embeddings into a unified part token.
flowchart TB
  top["Input Representation: Category Labels, 3D Point Clouds, 3D Bounding Boxes"]
  a["Part Node Encoder"]
  b["Relational Graph Transformer"]
  c["DETR-Style Slot Decoder"]
  base["Decoded Functional Graph: Completed Part Nodes and Typed Edges (contact, hinge, rail, attached)"]
  top --> a & b & c
  a & b & c --> base
Once encoded, these nodes pass into a fully connected Graph Transformer. Operating over a complete topology allows every existing component to attend globally to every other component. A drawer face attends to the surrounding cabinet carcass, recognizing the depth void where support rails must live; an unhinged vertical panel attends to the side wall frame where mounting plates must attach. This contextual propagation ensures that spatial voids and ungrounded kinematic pairings are recognized across the entire asset hierarchy.
To predict what is missing, GraFu couples the output of the Graph Transformer to a DETR-style slot decoder. A fixed bank of learnable query slots interacts with the contextualized part representations via cross-attention. Through bipartite matching during training, these slots are supervised to resolve two simultaneous targets:
- Per-Slot Node Prediction: Each query slot predicts whether it instantiates a missing physical component (e.g., an interior shelf, a missing cabinet top panel, or a handle), outputting its semantic class and canonical 3D bounding box.
- Per-Pair Edge Prediction: The decoder simultaneously classifies the pairwise relations connecting both existing and newly predicted nodes. Rather than outputting unconstrained numbers, it assigns typed mechanical relationships:
contact,hinge,rail, orattached, along with explicit motion ranges and limits.
By decoupling relational reasoning from raw polygon synthesis, the transformer guarantees topological consistency before a single vertex is modified. The model establishes where physical connectivity must exist and what mechanical family governs it, setting up the downstream geometric engine to snap real hardware into place.
Geometric Realization: Snapping Parametric Hardware to Rectify Kinematic Drift
A relational graph showing a hinge edge between two bounding boxes is still just mathematical bookkeeping. The breakthrough in GraFu’s pipeline lies in its two-stage geometric realization, which translates predicted graph topologies into watertight, collision-free physical assets.
flowchart TD
    Graph["Completed Functional Graph"] --> Split{"Realization Engine"}

    subgraph StaticPath ["Static Functionalization"]
        Split -->|Rigid Nodes| Infill["Volumetric Infilling"]
        Infill --> Tops["Top Panels (Chamfered, Rounded, Flat)"]
        Infill --> Shelves["Interior Dividers & Structural Shelving"]
        Infill --> Handles["Exterior Pull Handles"]
    end

    subgraph DynamicPath ["Dynamic Functionalization"]
        Split -->|Kinematic Edges| Hardware["Parametric Hardware Snapping"]
        Hardware --> Hinges["Snap C-Hinges, F-Hinges, P-Hinges"]
        Hardware --> Rails["Snap Slide Rails & Guides"]
        Hinges --> Ground["Mechanically Constrain Motion Axes"]
        Rails --> Ground
    end

    Tops --> Assembly["Unified Operable Asset"]
    Shelves --> Assembly
    Handles --> Assembly
    Ground --> Assembly
    Assembly --> Output["Collision-Free Articulated URDF / USD"]
The realization engine executes along two parallel paths:
Static Functionalization
Many open-source assets are missing non-movable structural geometry. Artists frequently model cabinets without top covers (assuming an architectural counter will hide them) or omit interior dividers entirely. When placed in simulation, objects placed inside these cabinets fall straight through the hollow floor.
GraFu’s static path takes the predicted rigid nodes and executes geometric infilling. It instantiates parametric surface primitives—generating cabinet top panels with user-specified edge profiles (rectangular, chamfered, or rounded), inserting load-bearing interior shelves, and mounting exterior handles at the predicted slot positions.
Dynamic Hardware Snapping and Motion Rectification
The dynamic path is where kinematic failure modes are permanently eliminated. Instead of accepting the noisy, floating rotation axes predicted by conventional joint estimators, GraFu snaps parametric connector templates directly into the interface boundaries between interacting parts:
- Rotational Hardware: The engine selects from a catalog of mechanical hinge templates (including C-hinges, F-hinges, and P-hinges). The hinge geometry is oriented and locked against the joint line between the door and carcass.
- Prismatic Hardware: For sliding drawers, the system instantiates explicit slide rails along the lateral shelf gaps, establishing physical translation guides.
Crucially, once these templates snap into place, the joint kinematics are no longer driven by abstract neural predictions. The hardware geometry itself dictates the mechanical axis of rotation and translation limits. Because the parametric hinge templates incorporate genuine offset distances, the door swings entirely clear of the side panel edge during opening sweeps, completely eradicating the mesh-on-mesh intersections that break physics simulations.
The Articulation Landscape: Virtual Kinematic Estimators vs. CAD Solvers vs. GraFu
When building asset ingestion pipelines for interactive simulation and embodied robotics, operators typically find themselves forced into one of three unsatisfactory compromises:
First, pure kinematic estimation models like OPD and Ditto take point clouds or segmented meshes and predict 3D axes and origins directly. The output is a mathematically pure vector hovering in a spatial void. Because no real mounting hardware is instantiated, the door panel swings around a phantom line, clipping through carcass trim or shearing across front edges.
Second, downstream simulation clamping attempts to compensate for these defects inside physics runtimes like Isaac Sim or SAPIEN. When an axis offset causes a door to bite into the frame, the engine detects the mesh-on-mesh intersection and clamps the allowable motion limit right before contact occurs. The asset becomes technically non-penetrating, but its usable range of motion is crippled—turning a cabinet designed for a ninety-degree swing into one that binds after opening fifteen degrees.
Third, generative CAD and assembly solvers like AutoMate approach the problem with manufacturing rigor, solving explicit mating constraints across planar surfaces and cylindrical fastener bores. In our work exploring generative solid modeling—such as going from prompt to printable STL—we see how explicit constraints maintain mechanical integrity. However, that rigor is precisely why CAD solvers fail on open-web assets: they require clean, manifold B-Rep boundary solids. Feed them an uncleaned polygon soup exported from Blender or Objaverse, and the constraint solver halts on the first non-manifold edge.
GraFu occupies a distinct and pragmatic trade-off space. It does not pretend dirty polygonal meshes are pristine STEP assemblies, nor does it settle for ungrounded virtual axes. By framing structural repair as graph completion and mechanically rectifying motion via snapped parametric templates, it accepts non-manifold visual geometry while enforcing genuine collision clearance.
| Paradigm | Missing Geometry Handling | Kinematic Realism | Input Mesh Tolerance | Pipeline Placement |
|---|---|---|---|---|
| Abstract Kinematic Estimators (OPD, Ditto) | None: Assumes all parts exist; cannot insert missing backboards, tops, or interior shelves. | Low: Hallucinates virtual axes in empty space; prone to mesh interpenetration and unconstrained drift. | High: Ingests raw point clouds and dirty polygonal meshes without topological constraints. | Upstream sensor perception or unguided mesh annotation. |
| Simulation Collision Clamping (Isaac Sim, PhysX) | None: Operates strictly on existing geometry by altering joint range attributes. | Degraded: Clamps angular travel prematurely to prevent collision, rendering assets functionally restricted. | High: Mesh-agnostic; operates downstream on convex hulls or collision meshes. | Downstream post-processing inside rigid-body physics engines. |
| CAD Mate Solvers (AutoMate, Joinable) | High: Manages complex multi-part parametric assemblies with standardized fasteners. | Exact: Produces mathematically grounded mating constraints and physically verified clearances. | Extremely Low: Demands watertight, manifold B-Rep solids; fails entirely on raw polygon meshes. | Standalone CAD authoring and precision mechanical synthesis. |
| Functionalization (GraFu) | High: Dual-mode completion instantiates rigid panels and snaps dynamic hardware connectors. | High: Motion is mechanically constrained by snapped hardware templates, guaranteeing door clearance. | Medium: Requires part-segmented meshes with category labels and 3D bounding boxes. | Mid-pipeline asset conditioning bridge for simulation environments. |
Where GraFu Breaks in Production: Upstream Segmentations, Jammed Pins, and Tolerance Traps
While GraFu’s relational graph formulation resolves the virtual-axis illusion, deploying it into an automated production pipeline exposes several brittle engineering friction points. The system is fundamentally an asset conditioner, meaning upstream noise or unaddressed geometric tolerances quickly cascade into broken physics.
The primary failure point occurs upstream of the graph representation itself. GraFu expects clean, pre-partitioned part nodes equipped with accurate bounding boxes and point clouds. In practice, visual assets from open repositories or photogrammetric captures arrive as single, collapsed meshes with chaotic draw calls. If an automated upstream segmentation model bleeds a drawer front into the surrounding carcass geometry, GraFu receives corrupted node features. The graph transformer cannot attend to a structural void if that void is merged into a solid polygon clump.
Downstream in the architecture, the DETR-style slot decoder introduces matching instabilities across non-standard geometries. Bipartite matching performs reliably on standard single-door cabinets, but it degrades on asymmetric sideboards, bi-fold panels, or stacked drawers with irregular vertical pitches. The slot decoder frequently under-predicts—omitting a secondary hinge on a tall panel—or hallucinates ghost slide rails inside solid base frames.
The most severe operational risk, however, occurs during template snapping. In rigid-body physics engines like PhysX, Isaac Sim, or MuJoCo, multiple revolute joints constraining a single rigid body must have their hinge pin axes aligned with near-perfect mathematical co-linearity. Because GraFu snaps parametric templates based on localized bounding box heuristics, an off-axis face or slightly warped mesh can tilt one hinge pin by a fraction of a degree relative to its mate. To a visual renderer, a one-degree tilt is completely undetectable; to a rigid-body solver, non-coaxial hinge pins create an overconstrained kinematic lock that freezes the door completely.
Furthermore, visual 3D assets are routinely modeled with zero clearance—drawers fit flush against cabinet walls without a millimeter of gap. Snapping hardware without carving out clearance pockets causes immediate interpenetration and impulse explosions upon spawning. Coupled with the complete absence of mass, inertia tensor, and friction modeling, an unassisted GraFu asset will easily tip over or explode during simulation unless wrapped in rigorous validation tooling.
| Pipeline Stage | Operational Failure Mode | Production Mitigation Strategy |
|---|---|---|
| Upstream Segmentation | Monolithic mesh collapse and blurry semantic boundaries merge movable panels into static frames. | Implement mandatory mesh healing and zero-shot 3D part partitioning (e.g., SAM-3D or PartSLIP) before graph tokenization. |
| Slot Decoding | Bipartite matching under-predicts dual hinges or predicts ghost rail slots inside solid cabinet carcasses. | Enforce deterministic topological rules (e.g., revolving doors must instantiate $\ge 2$ coaxial hinges; drawers require bilateral rails). |
| Template Snapping | Sub-degree angular misalignment between multiple hinge pins creates overconstrained kinematic locks in PhysX/MuJoCo. | Apply an analytical post-snapping pass that projects all collinear hinge pin vectors onto a single shared directional axis. |
| Boolean Realization | Automated carving of hinge pockets and rail slots on dirty meshes generates non-manifold geometry and inverted normals. | Decouple visual meshes from simulation dynamics; snap simplified convex collision hulls rather than executing exact Booleans on raw visual meshes. |
| Simulation Import | Zero-clearance interpenetrations and missing inertia tensors cause explosive impulses or unbalanced asset tipping. | Run a headless CI/CD testbed that actuates every joint across its full travel range, checks energy spikes, and injects procedural density priors. |
Practical Implementations: Three Production Workflows Built Around Functionalization
Transitioning GraFu from an academic prototype into a production asset factory requires surrounding the core graph transformer with deterministic pre- and post-processing stages. If you are building ingestion pipelines for embodied robotics, the most immediate architecture to deploy is an Automated Objaverse-to-URDF Conditioning Pipeline. This ingestion worker takes raw, unstructured visual meshes from static repositories, passes them through zero-shot 3D part segmenters like SAM-3D or PartSLIP, and feeds the resulting part tokens into GraFu for connector snapping and structural infill. Downstream, an automated Boolean mesh-pocket generator carves mortises before compiling verified URDF and OpenUSD packages for Isaac Sim and SAPIEN. The critical failure mode I monitor here is upstream segmentation drift: if a drawer boundary bleeds into the surrounding frame, the resulting disconnected carcass hull ruins graph tokenization. Furthermore, because GraFu outputs purely geometric completions without physical dynamics, the pipeline must inject procedural density distributions; otherwise, simulated cabinets will tip forward the moment heavy cantilevered drawers extend.
For teams managing high-fidelity industrial digital twins, the default C, F, and P hinge templates are often too primitive. Here, I recommend architecting a Parametric Hardware Swapping and Custom Hinge Infiller. By decoupling GraFu’s slot decoder edge predictions from its geometric realization step, you can bind the predicted joint locations to a custom catalog of manufacturer STEP and B-Rep hardware—such as concealed cup hinges or multi-stage ball-bearing drawer slides. The workflow routes relational graph predictions into an automated mesh clearance carver that pockets the carcass and exports directly via OpenUSD Physics schemas. The operational trap to watch for in this pipeline is tolerance mismatch: swapping in realistic multi-pivot hardware on models authored with zero nominal clearance inevitably produces door-to-frame intersections. Without programmatic panel mortising and gap clearance compensation, the resulting asset triggers continuous collision impulse spikes in rigid-body solvers.
Finally, no functionalized asset should reach an embodied agent's training environment without passing through an Automated Kinematic Integrity and Jamming CI/CD Testbed. This headless validation harness parses exported GraFu URDFs into a physics engine like MuJoCo or Bullet, using a joint trajectory controller to sweep every revolute and prismatic joint through its full operating range. An automated diagnostic dashboard monitors internal torque spikes, penetration events, and sudden energy jumps. This regression step is vital because visual inspection cannot detect sub-degree angular misalignments across paired hinge pins on a single door. In a visual renderer, a fraction of a degree of pin tilt looks flawless; in a rigid-body solver, the non-coaxial constraint creates an immediate kinematic lock that freezes the joint solid. Catching these geometric binds early prevents silent policy corruption during large-scale robotic reinforcement learning.
Scaling Mechanical Inductive Biases Beyond Furniture
Furniture is the low-hanging fruit of mechanical functionalization. Cabinetry obeys clean rectilinear layouts, predictable component hierarchies, and simple 1-DoF revolute and prismatic joints. But the physical world that robotic manipulation agents must navigate—and that simulation engineers must model—is not composed exclusively of wardrobes and credenzas. The next frontier for relational graph functionalization lies in scaling these mechanical inductive biases into complex consumer electronics, industrial equipment, and automotive assemblies.
In these advanced domains, simple single-pin hinges and rigid slide rails fall short immediately. Real mechanical mechanisms rely heavily on compound motion: vehicle hoods and trunk lids articulate via four-bar linkages that simultaneously lift and translate the panel outward to clear aerodynamic bodywork. Laptop screens and foldable devices depend on torque-tuned friction clutches that maintain arbitrary opening angles against gravity rather than swinging freely. Enclosures and battery compartments rely on compliant snap-fit latches that flex elastically before locking into detents. Attempting to approximate a multi-linkage hinge with a single-axis revolute joint guarantees either severe mesh collision or an unphysical pivot point floating far outside the chassis.
To bridge this gap, the community must expand its catalog of inductive mechanical templates beyond static rigid hardware into multi-body kinematic subgraphs. Rather than predicting a single hinge edge between two rigid bodies, the slot decoder must learn to instantiate closed kinematic loops—predicting intermediate rocker arms, pivot pins, and coupled mechanical constraints. Where parametric templates cannot cover bespoke geometries, we will need hybrid neural-symbolic solvers that synthesize localized kinematic mechanisms directly satisfying clearance and path-following objectives.
For simulation and robotics teams, the strategic takeaway is clear: do not treat object functionalization as a monolithic end-to-end model. Instead, position your asset conditioning infrastructure around decoupled, modular abstraction boundaries. The relational graph completion layer—which reasons over part topologies, missing structural panels, and mechanical relationships—must remain strictly decoupled from the geometric realization engine that instantiates hardware and solves kinematics. By architecting this separation today, teams can readily swap simple furniture templates for sophisticated linkage solvers, compliant mechanism engines, and domain-specific CAD catalogs tomorrow, transforming static visual repositories into an inexhaustible supply of physically operable, training-ready worlds.
Resources
Updated 2026-09-17 by Mehran Mozaffari.
Related posts
29 October 2026
How Qwen3.5-4B-3D-Coder Generates Interactive 3D Scenes Without Loading a Single Mesh
29 October 2026
How 3D OS Turns a Coding Agent into a Six-Department Animation Studio Without a GUI
26 October 2026
AudioLift and the Illusion of Rigless 3D Avatars
5 October 2026
Deconstructing Pi: Architecture, Context Compaction, and Codemode Mechanics in an Extensible Agent Harness
24 September 2026
Dense 3D Tracking Across Thousand-Frame Horizons: An Operator's Breakdown of TrackEverything
22 September 2026
Inside xvr: Cracking Sub-Second 2D/3D Surgical Registration with Patient-Specific Foundation Models